Precise motion solution built around Cartesian robots
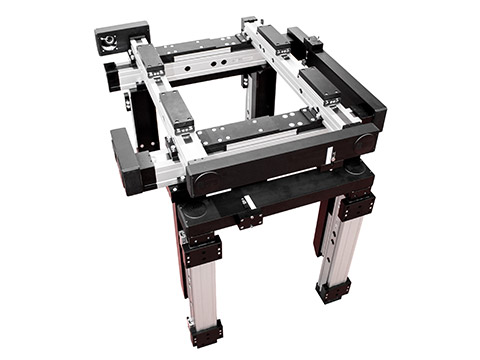 When Laboratoire EM2C, a leading scientific research laboratory needed a new XYZ positioning table designed to precisely move a heavy 100kg load at low speeds, it was IMI’s Industrial Automation team it turned to.
The requirements were unique and highly demanding. Firstly, spatial constraints meant the table needed to have a very compact footprint – less than 1,000×1,000×1,000 mm. Strokes needed to be optimised for each axis, ranging from 150 to 250 mm across each of the X, Y and Z axes. Meanwhile, positioning repeatability of ±0.025mm was also required throughout.
The customer’s need was for a complete turnkey solution comprising brushless motors, drives and communication interfaces which were all fully compatible with the research centre’s IT standards, as well as the expert technical support critical to optimising overall system performance.
This made the choice of motor and control partner from the outset absolutely critical. To support the customer, IMI’s Industrial Automation team collaborated with ROSIER Mécatronique, a proven partner able to deliver all the motors, drives, control systems and commissioning support, while IMI specified its IMI Bahr Q series linear axis with spindle drive and rail guide for the bespoke mechanical aspects.
The engineering challenge would be a complex one if the defined strokes and other criteria were to be satisfied, requiring the combined knowledge of both the IMI and ROSIER Mécatronique teams.
The project team explored a number of XYZ Cartesian robot concepts. In all, a total of seven layout versions were designed, reviewed, modified and refined, with each design iteration reviewed in detail at technical validation meetings involving IMI, ROSIER Mécatronique and Laboratoire EM2C. After each of these meetings, an updated 3D design was created and supplied within a few days.
The final design comprised four parallel, synchronised vertical (Z) legs. This concept had originated with the customer, but implementing it demanded significant engineering input and creativity from IMI’s design team.
The objective was a mechanical system in which the X, Y and Z axes would not collide with or obstruct each other, while allowing for mechanical adjustments during assembly and final commissioning.
In particular, the team had to combine mechanical synchronisation – pulleys and toothed belts – with a virtual synchronisation strategy, whereby the axes were synchronised in pairs, with each axis stroke adjusted to the hundredth of a millimetre.
The result is a fully integrated XYZ package which is now being commissioned and has been well received by the customer, who has already placed a further order for two similar tables to be delivered later this year to deliver greater testing capacity.
The evolution of the final solution through multiple iterations reflected the sustained commitment, technical capability and dedication within IMI and ROSIER Mécatronique teams to finding the best possible outcome.
Pierre Claudel, Key Account Manager at IMI, explained: “Over decades, we have supported many projects where the demands for robustness and handling large, heavy items must be seamlessly combined with extremely high levels of accuracy and repeatability.
“The ability to collaborate with specialist partners to fulfil these exacting project needs is so often crucial to our success and this was very much in evidence here, with our collaboration with ROSIER Mécatronique bringing together two highly proficient expert teams to design and then bring to life the final solution.”